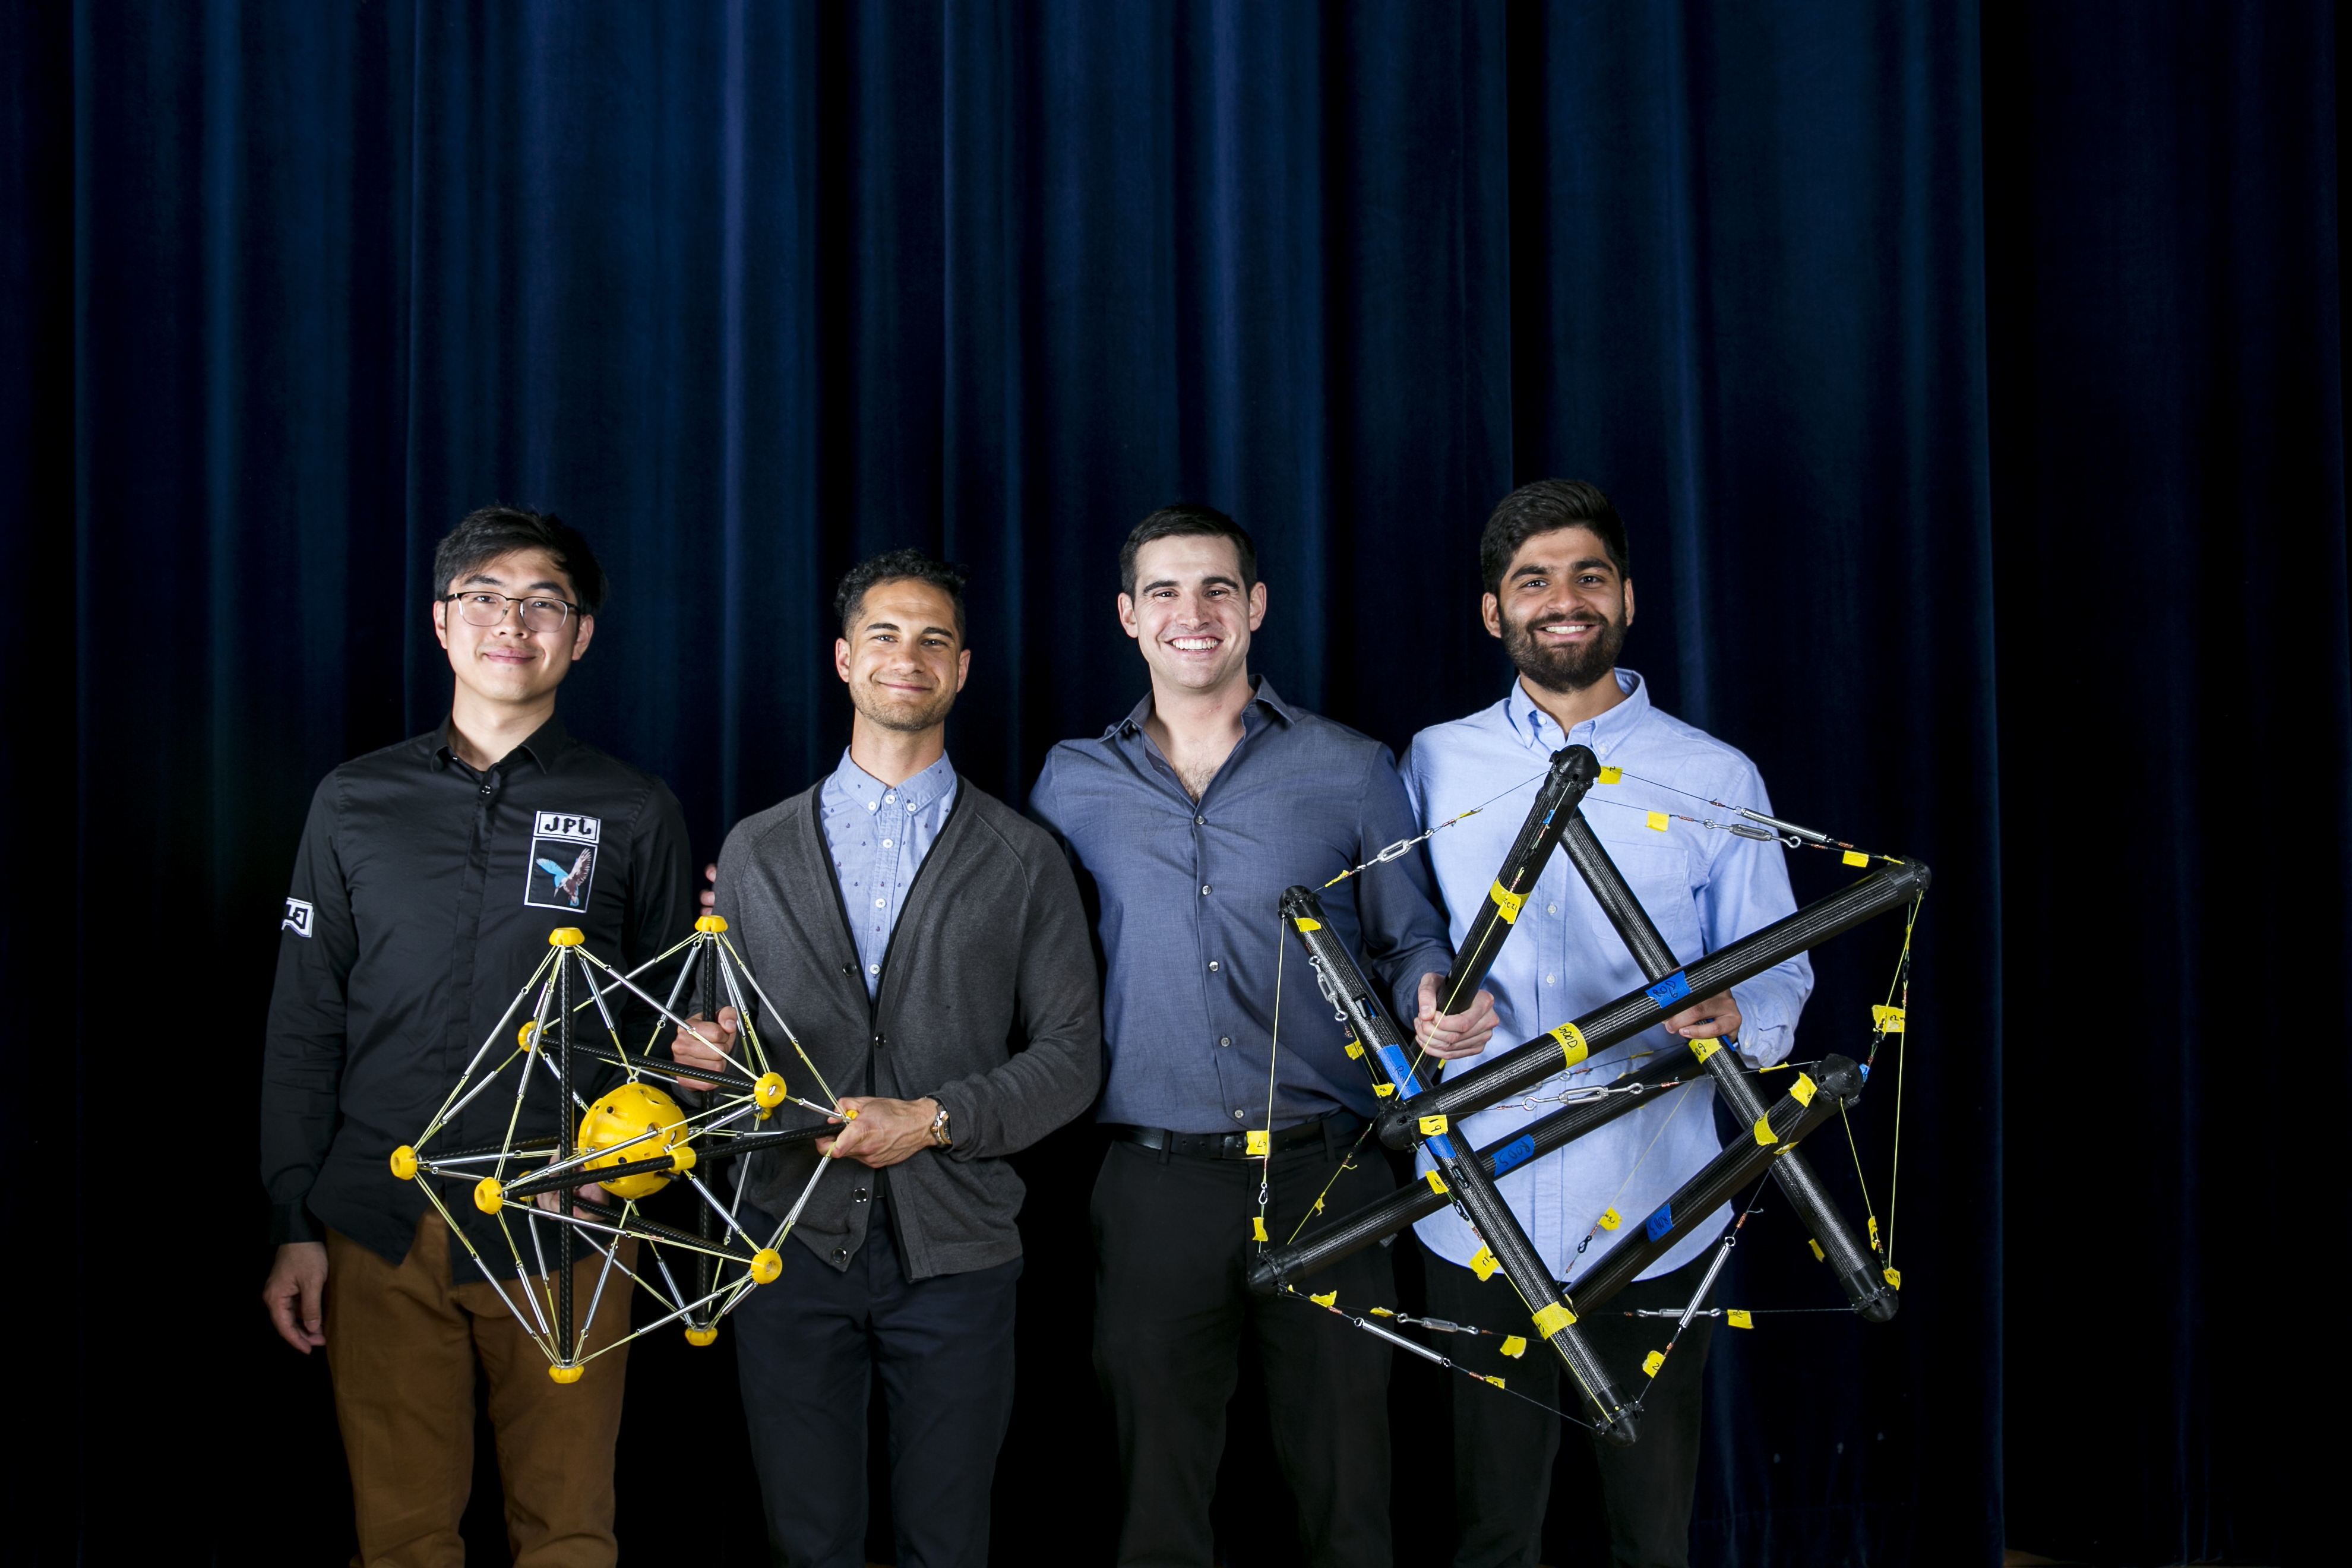
Squishy Robotics builds rapidly deployable mobile sensing robots for disaster rescue, remote monitoring and space exploration.
Over the course of my master’s degree at UC Berkeley, I completed various projects as part of my capstone experience:
- Developed and integrated a path planning technique using A* and MPC for a tensegrity robot in Simulink
- Increased range of radio communication by 200% by integrating long-range radios into the robotics system
- Developed software that allowed interchangeable use of different frequency radios